Projects & Open Source Contributions
A selection of personal, open-source, research, and robotics engineering projects I've built and contributed to.
Memory Optimization in Newton Raphson Power Flow (Power Grid Model)
Optimized sparse factorization for Newton-Raphson Power Flow in the Power Grid Model C++ library by localizing the Jacobian matrix to L3 cache, reducing cache misses by 0.8% and eliminating per-solver-instance working set overhead, removing transient peak memory growth entirely.
View Pull Request #1433 ↗
Chatbot with embeddings
Developing a chatbot leveraging embeddings and vector search to optimize LLMs for specialized research topics.
The user interface and backend logic are fully operational while integrating custom document embeddings.
See it here! ↗
Neural Architecture Search using Reinforcement Learning
Built an RL-driven neural architecture search pipeline (TRPO and PPO training a recurrent controller) to automatically design GNN architectures for the CiteSeer dataset, matching the original hand-designed method's 73.6% mean validation accuracy without manual tuning.
See it here! ↗
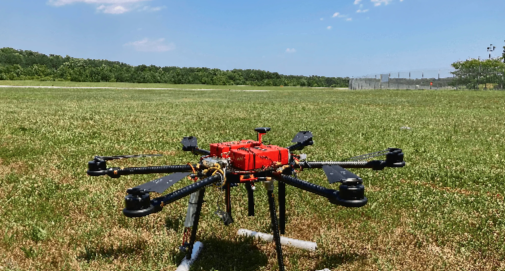
Seraphim Autonomous Hexacopter
An autonomous hexacopter based on the PX4 flight stack, capable of autonomous waypoint navigation and object detection via a camera module.
Seraphim maintains a thrust-to-weight ratio of 2:1 during take-off and carries a payload of up to 7 kg. Developed at Project MANAS.
See it here! ↗
KOBU Multi-Robot Coverage
A multi-robot coverage planning system composed of 3 differential-drive robots utilizing space-filling curves (Peano & Hilbert curves).
Implemented using ROS, Gazebo, and C++.
See it here! ↗
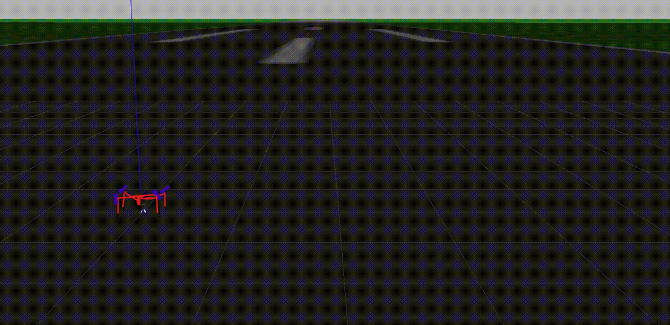
Drone Simulation (DPO)
Built a simulation to visualize quadcopter flight in Gazebo using ROS.
Created a Software-In-Loop (SITL) testbench sending coordinate vectors in C++ to the PX4 flight stack.
See it here! ↗
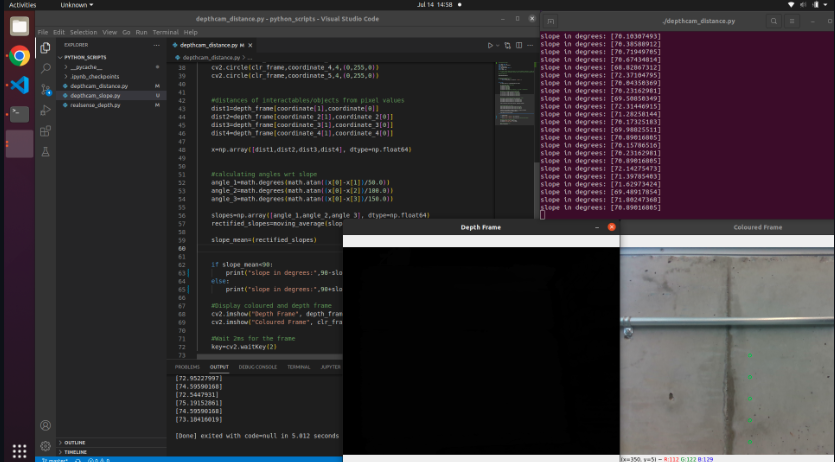
Visual Slope Detection
Implemented slope detection of incident surface obstacles using an Intel RealSense depth-camera sensor in Python and OpenCV, publishing calculated slope angles over ROStopics.
See it here! ↗
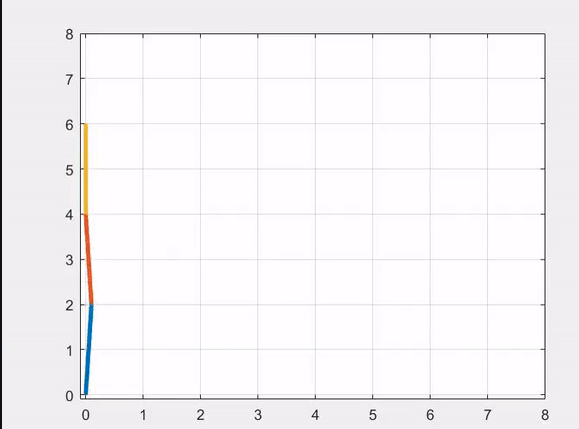
Iterative Inverse Kinematics
Iterative inverse kinematics solver using Jacobian matrices and Newton-Raphson root solving methods to achieve convergence for a 3 DoF RRR robotic arm.
See it here! ↗
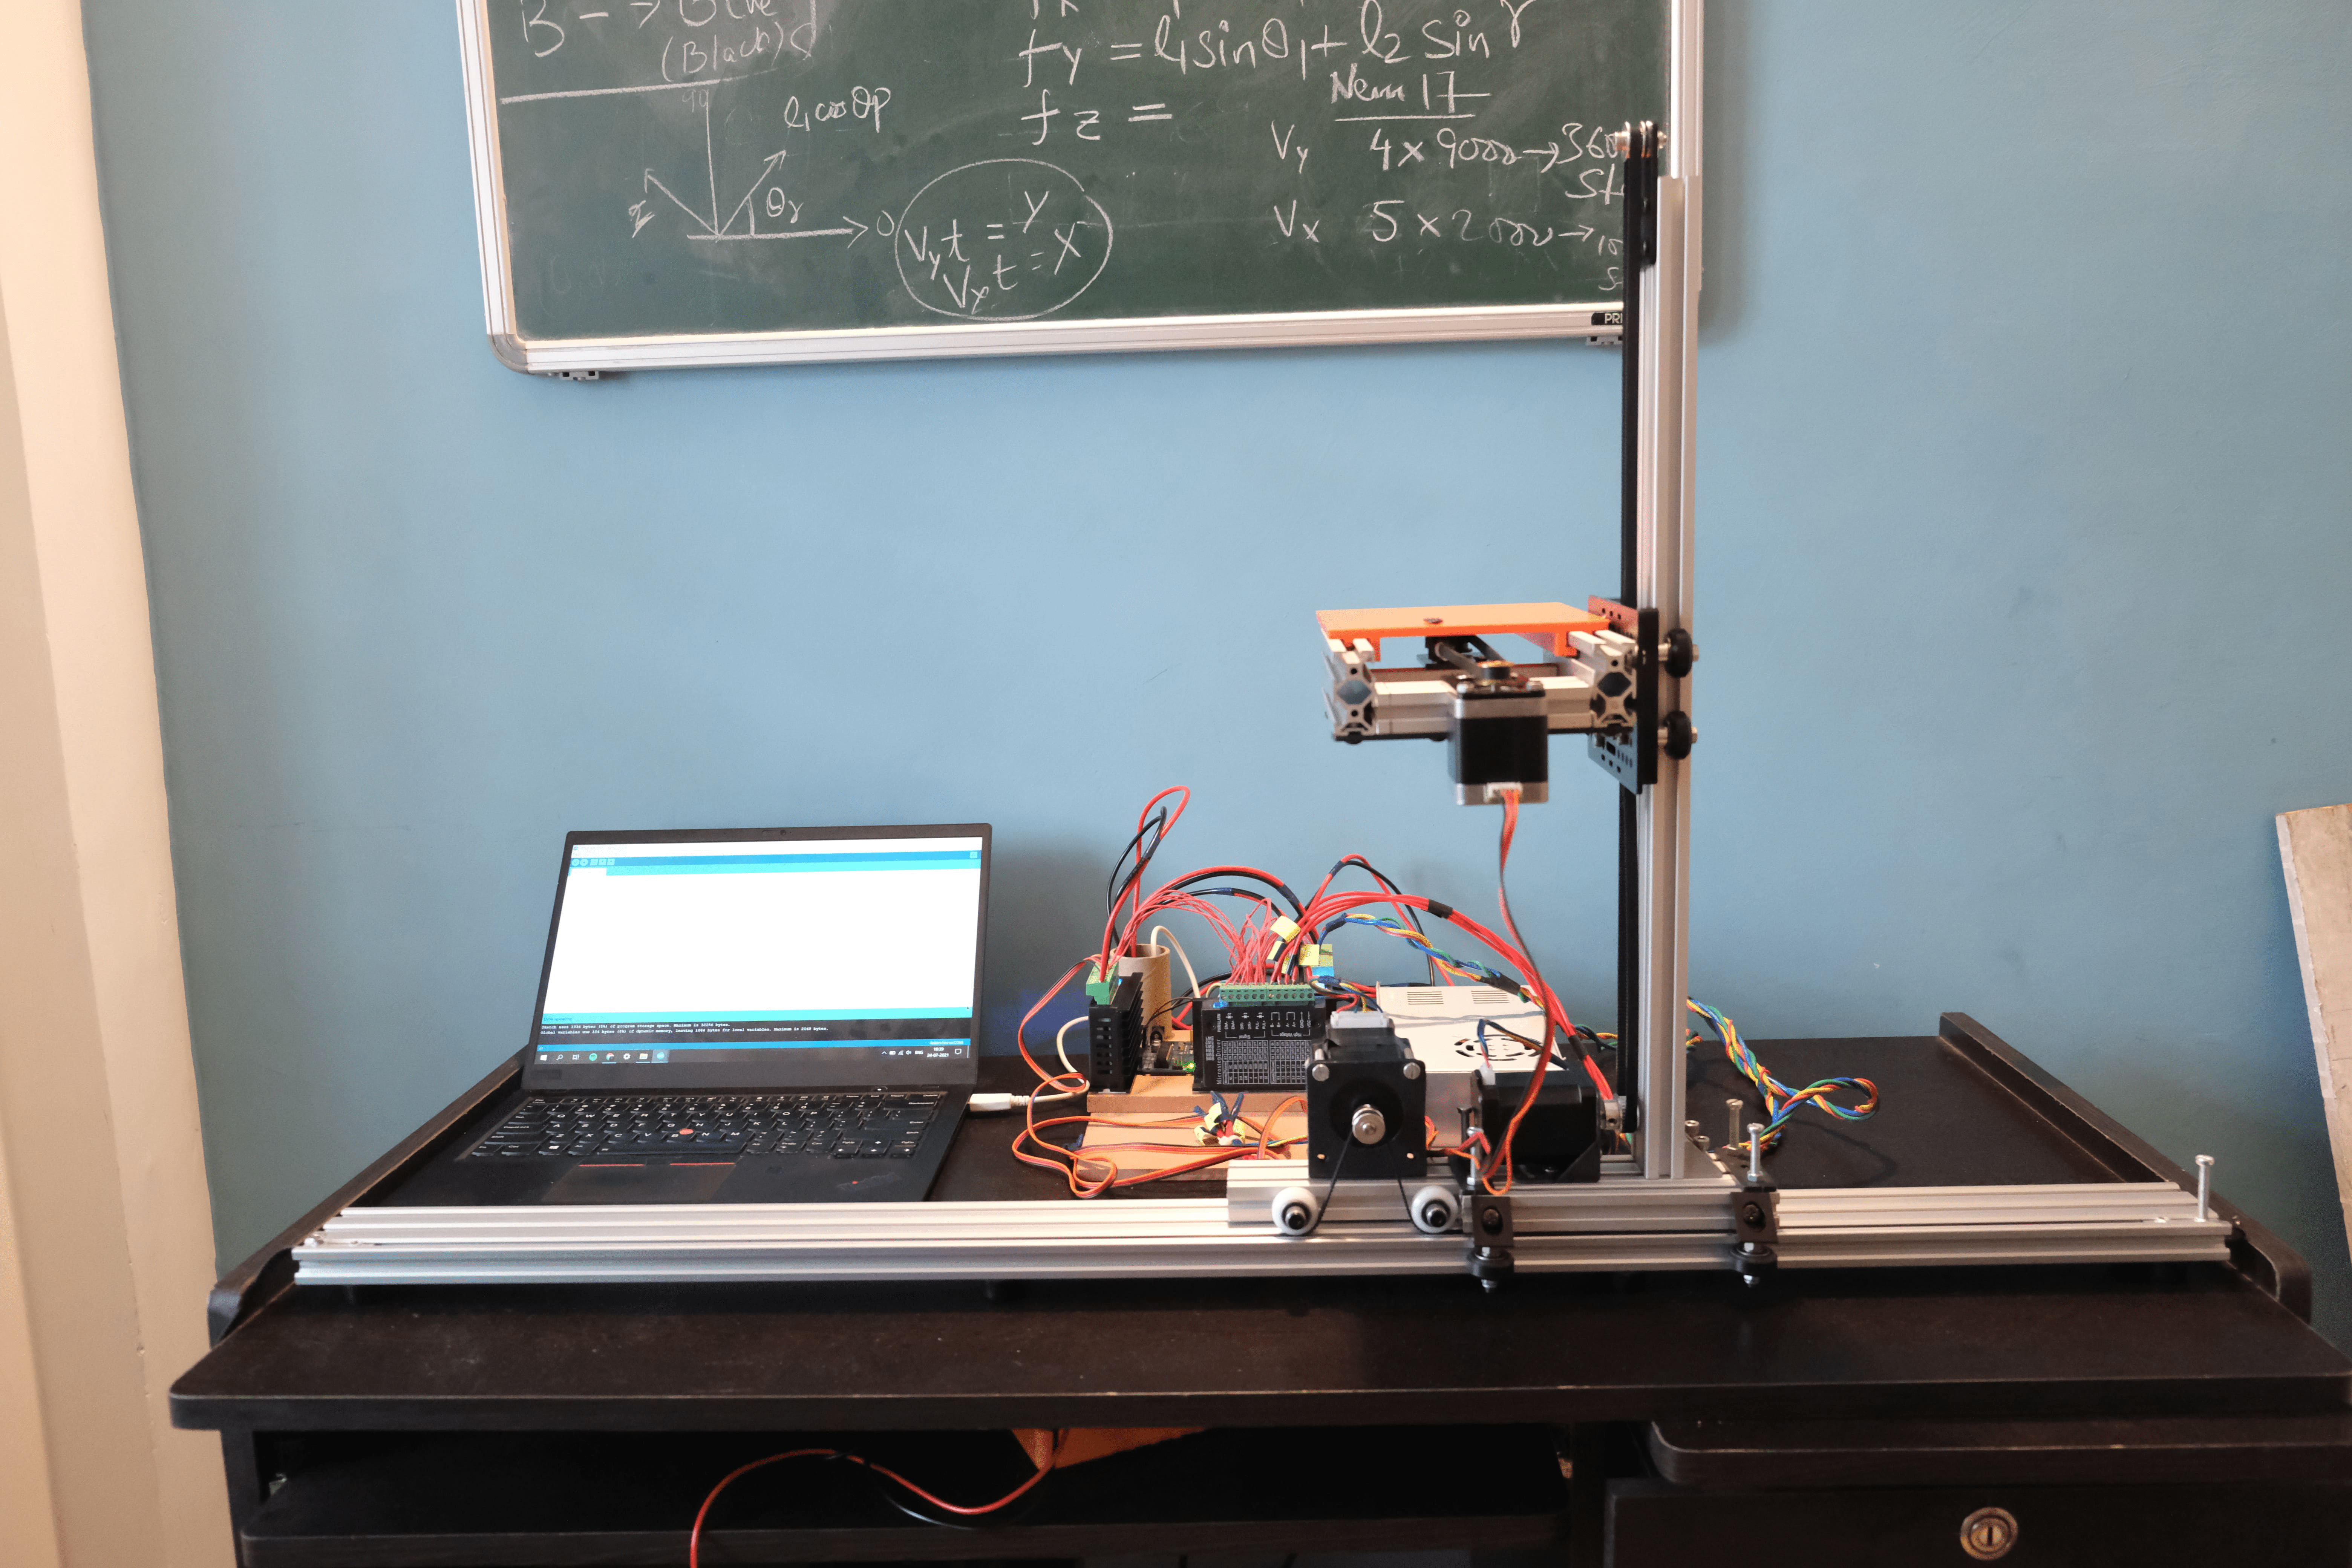
SHELFY Warehouse Automation
National semi-finalist (Top 100 out of 3000+ teams) in the Swadeshi Microprocessor Challenge by the Govt. of India.
Built a smart automated storage and retrieval system for warehouse automation using an indigenous FPGA board.
See it here! ↗